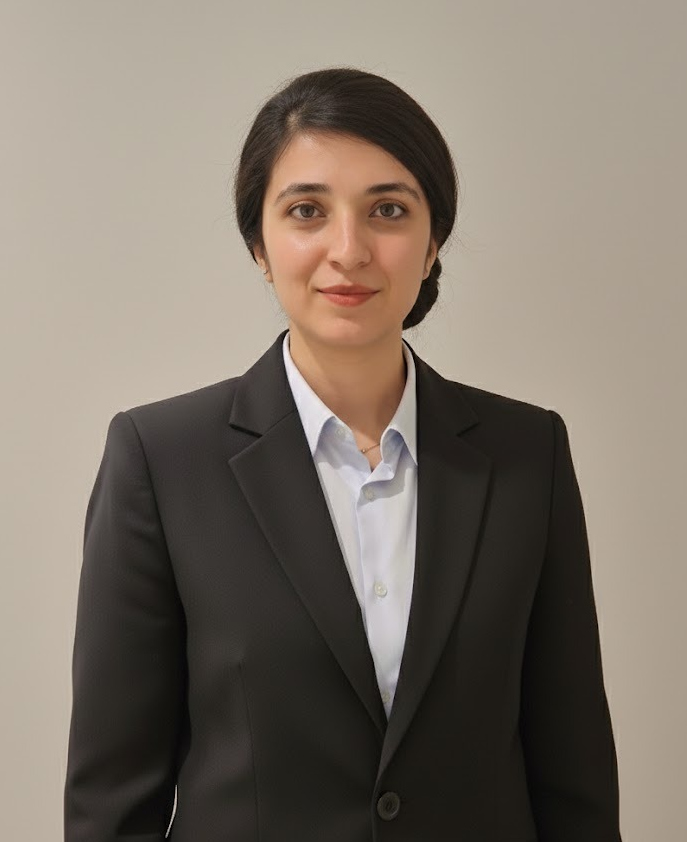
Master of Science Aqsa Rahim will hold the Trial Lecture and Thesis Defense for the PhD degree in Science on Tuesday, December 1, 2026.
Trial Lecture
Takes place 10:15 - 11:15.
« Cyber-physical systems and communications of low altitude drones »
Thesis Defense
Takes place 12:15 - 15:00.
« Detection and Slipperiness Estimation of Road Using Multi-Sensor and Vision Data in Arctic Conditions »
Abstract
Autonomous vehicles operating in Arctic regions could face challenges due to snow and ice-covered roads, low vision, and rapidly changing weather conditions, all of which negatively impact sensor reliability and decision-making. In autonomous driving, safe navigation plays a significant role, which could be achieved with reliable detection of drivable paths and evaluation of road slipperiness. However, the current studies lack a multi-sensor dataset that includes a wide range of driving scenarios in Arctic regions in varying environmental conditions. To address these challenges, this thesis proposes a solution for collection, integration, and analysis of multi-sensor data obtained in Arctic driving environments. This thesis has improved perception and environmental awareness in Arctic driving environments by combining multi-sensor data.
The challenges of autonomous driving in Arctic environments have addressed in this thesis by developing a methodology for collection, integration, and analysis of multi-sensor data. The multi sensor data was collected from Arctic road-driving environments using sensors including LiDAR, environmental, friction, and camera sensors. This multimodal sensor data provides a way to improve perception and environmental awareness of autonomous driving in Arctic environments.
In this thesis, two perception modules are developed, one for path detection and one for slipperiness level prediction, to improve the reliability, safety, and interpretability of autonomous driving in arctic regions. The first perception module considered vision data collected by the camera that was used to detect drivable paths in Arctic region. This module was created by contributing to the YOLOv8 architecture, resulting in a more reliable and efficient model. Whereas, the second perception module was developed based on LiDAR intensity, environmental, and friction sensor measurements to predict road slipperiness for autonomous driving in Arctic regions. This module was built using a fuzzy logic based approach to estimate the degree of slipperiness of road surfaces in Arctic regions. A physics-based model was also developed to evaluate this perception module to improve the interpretability of the sensing process by describing surface-dependent light material interactions.
This thesis’s contribution provide a comprehensive methodology for Arctic regions that combines data collection, multi-sensor fusion, deep learning-based path detection, and physics-informed slipperiness estimation. The combined output allows autonomous vehicles in adverse weather conditions to drive with real-time, risk-aware decision support.
Supervisory Committee
- Associate Professor Fuqing Yuan, Department of Technology and Safety, UiT The Arctic University of Norway (Main Supervisor)
- Professor Javad Barabady, Department of Technology and Safety, UiT The Arctic University of Norway
- Professor Bjørn-Morten Batalden, Department of Technology and Safety, UiT The Arctic University of Norway
Evaluation Committee
- 1st Opponent: Professor Dr. Lyudmila Mihaylova, School of Electrical and Electronic Engineering, The University of Sheffield, United Kingdom
- 2nd Opponent: Professor Chunming Rong, Department of Electrical Engineering and Computer Science, University of Stavanger, Norway
- Internal member and leader of the committee: Associate Professor Amar Aganovic, Department of Automation and Process Engineering, UiT The Arctic University of Norway
Streaming
The Trial Lecture and Thesis Defense will be streamed via Panopto:
Trial Lecture (10:15 - 11:15)
Watch the Trial Lecture
Thesis Defense (12:15 - 15:00)
Watch the Thesis Defense
Thesis
When: 01.12.26 at 10.15–15.00
Where:
Auditorium 1.022, Teknologibygget
Location / Campus: Digital, Tromsø
Target group: Employees, Students, Guests, Invited, Unit
E-mail: daniels.sliks@uit.no